Junzhe Hu

PhD Student, Department of Electrical Engineering and Computer Science
Massachusetts Institute of Technology
  • Robotics
  • Computational design
  • Computational physics
  • Control
  • Embodied perception

About

I am a PhD student in Electrical Engineering and Computer Science at the Massachusetts Institute of Technology, advised by Prof. Kevin Chen, and collaborating with Prof. Zachary Manchester on constrained optimal control and lightweight optimization-based controllers for robotic systems. Previously, I received my M.S. in Robotics from the Carnegie Mellon University Robotics Institute, where I was co-advised by Prof. Carmel Majidi and Prof. Zachary Manchester.

My research asks how robots can perceive, understand, and exploit the environments they are physically coupled to. A robot moving through fluid or contact does not just act on its surroundings; the surroundings act back. I study this robot–environment interaction through computational physics and computational design, building differentiable multiphysics models of the coupling and co-designing body and controller against them. The goal is robots that sense the forces they feel and plan and control to harness these interactions instead of rejecting them.

My work spans the two extremes of this problem: robots so constrained that every bit of sensing and computation counts, and bodies that exploit their environment with no controller at all. Between them lies one design question: how much of a robot’s intelligence should live in its controller, and how much in its body and the physics around it.

News

Projects

Ongoing

Swarm RoboBee

Two soft-actuated RoboBees collide mid-air, then recover and land under closed-loop control.

For control
Robust to a large impulsive disturbance, not just small perturbations.
For planning
Collision becomes recoverable rather than forbidden, so swarms can fly denser.
Soft and Micro Robotics Lab, MIT Filmed at 1000 fps
3D Fluid–Robot Multiphysics Simulator

Taking our unified fluid–robot framework from 2D to 3D on the GPU: a differentiable, two-way coupled immersed-boundary solver, with flapping-wing flight as its first application.

GPU · differentiable · two-way coupled
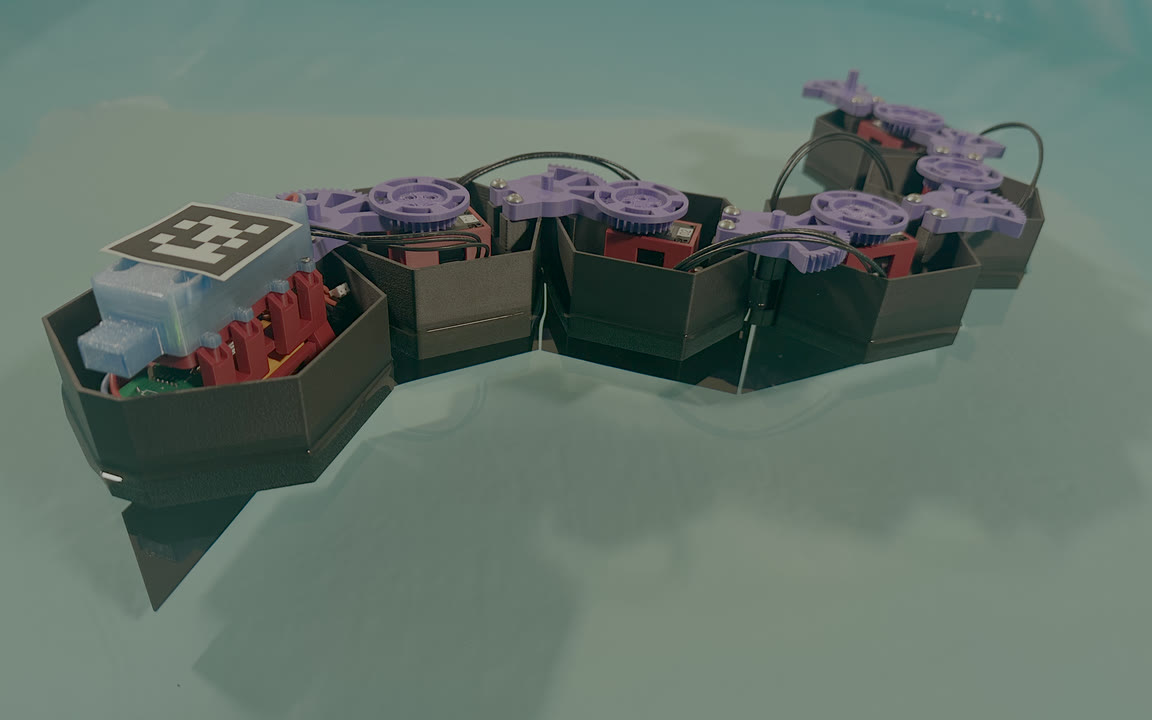
Modular eel robot with onboard electronics floating in a test tank

Eel Robot with Onboard Sensing

Giving our untethered, modular eel robot a sense of its own body and the surrounding flow, so that what it feels can be fed back into control and planning.

Untethered · modular · onboard sensing
Selected papers
* equal contribution

RSS 2026 · Outstanding Paper Award Finalist

Unified Fluid–Robot Multiphysics

Fluid and robot dynamics posed as one least-action problem, giving a differentiable simulator whose swimming gaits and C-start escapes transfer to an untethered eel robot.

Realizing Robotic Swimming with Unified Fluid–Robot Multiphysics
J. H. Lee*, J. Hu*, S. Kwok, C. Majidi, Z. Manchester

npj Robotics · 2026

Programmable Stiffness for Aquatic Locomotion

A modular multi-link swimmer that tunes joint stiffness online through sliding laminate flexures; trajectory-optimized stiffness patterns raise thrust by up to 89%.

Programmable online stiffness modulation for optimized aquatic locomotion
J. Hu, J. H. Lee, T. Wu, G. N. Sue, J. Liao, Z. Erickson, Z. Manchester, C. Majidi

PNAS · Under review

Vortex-Induced Upstream Swimming

A passive, segmented “dead-fish” robot that synchronizes with an oncoming vortex street to harvest flow energy and move upstream, with stiffness distributions found by gradient-based design.

Vortex-Induced Propulsion in Upstream Robotic Swimming
J. H. Lee*, J. Hu*, S. Kazi, M. Luhar, C. Majidi, Z. Manchester
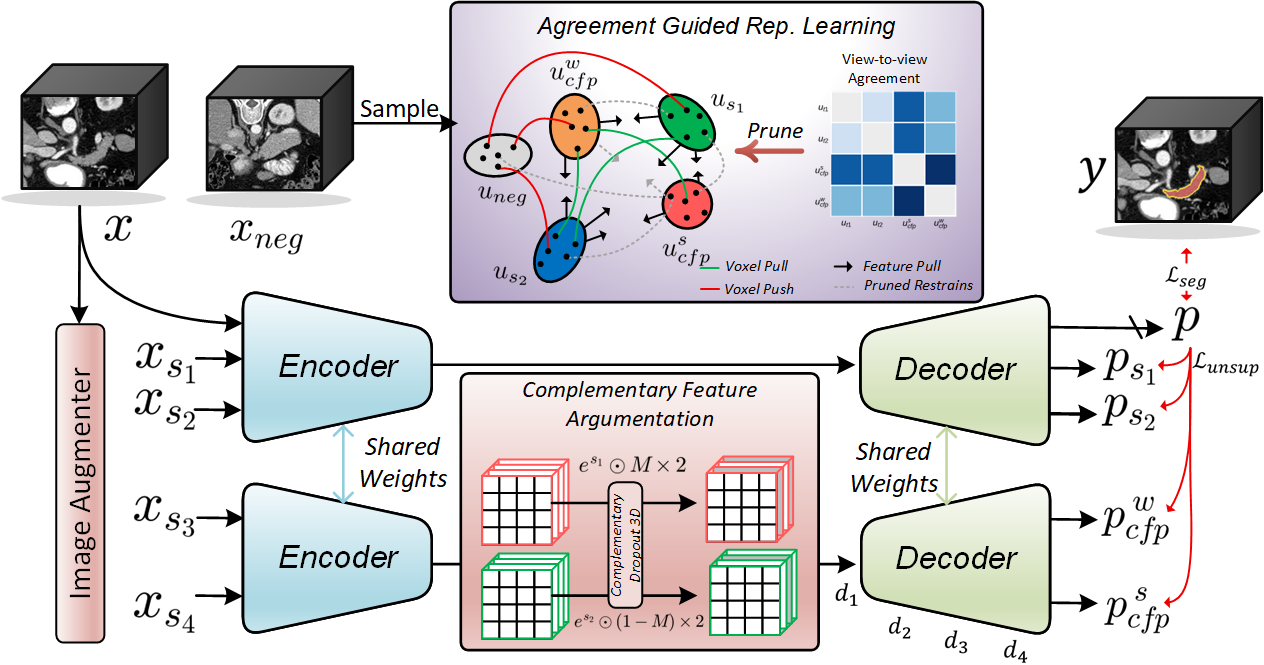
RepMatch framework for semi-supervised medical image segmentation

WACV 2026 · Under review

Label-Efficient Medical Image Segmentation

Agreement-guided representation learning that curbs pseudo-label noise when only a few annotated scans are available.

RepMatch: Agreement-Guided Representation Learning for Semi-Supervised Medical Image Segmentation
Y. Wen, J. Hu, E. Roussinova, M. Bouri

All publications